DANiLab
DANiLab
Team
Publications
Robots + Hardware
News
Join the lab
1
Embodied Interpretability: Linking Causal Understanding to Generalization in Vision-Language-Action Models
Hanxin Zhang
,
Mingshuo Xu
,
Abdulqader Dhafer
,
Shigang Yue
,
Hongbiao Dong
,
Zhou Daniel Hao
PDF
Project
Source Document
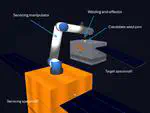
De-Risking Robotic Welding for In-Space Metal Joining Through Physics-Grounded Digital Twins
Accepted for oral presentation at IAC 2026. The paper will be available after the congress (October 2026).
Zhou Daniel Hao
,
Umer Masood Chaudry
,
Robert Shaw
,
Andrew Cheney
,
Nick Ludford
,
Mark Sims
,
Hongbiao Dong
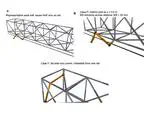
Structural–Robotic Co-Design of Welding-Enabled Orbital Infrastructure for In-Space Assembly
Accepted for oral presentation at IAC 2026. The paper will be available after the congress (October 2026).
Zhou Daniel Hao
,
Umer Masood Chaudry
,
Ehsan Simaei
,
Robert Shaw
,
Richard Hampson
,
Andrew Cheney
,
Nick Ludford
,
Mark Sims
,
Hongbiao Dong
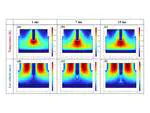
3D Heat Transfer and Electromagnetic Model of Arc Welding in Outer Space Environment
Accepted for oral presentation at IAC 2026. The paper will be available after the congress (October 2026).
Umer Masood Chaudry
,
Richard Hampson
,
Andrew Cheney
,
Nick Ludford
,
Robert Shaw
,
Mark Sims
,
Hongbiao Dong
,
Zhou Daniel Hao
Intent-Handover: Grounding Language in Human-Usage Regions for Trustworthy Robot-to-Human Handovers
Hanxin Zhang
,
Abdulqader Dhafer
,
Hongbiao Dong
,
Zhou Daniel Hao
PDF
Project
R2HandoverSim: A Simulation Framework and Benchmark for Robot-to-Human Object Handovers
Hanxin Zhang
,
Abdulqader Dhafer
,
Hongbiao Dong
,
Zhou Daniel Hao
PDF
Project
Cite
×